Concept development
NukeRobot™
Nuclear Robotic Inspection
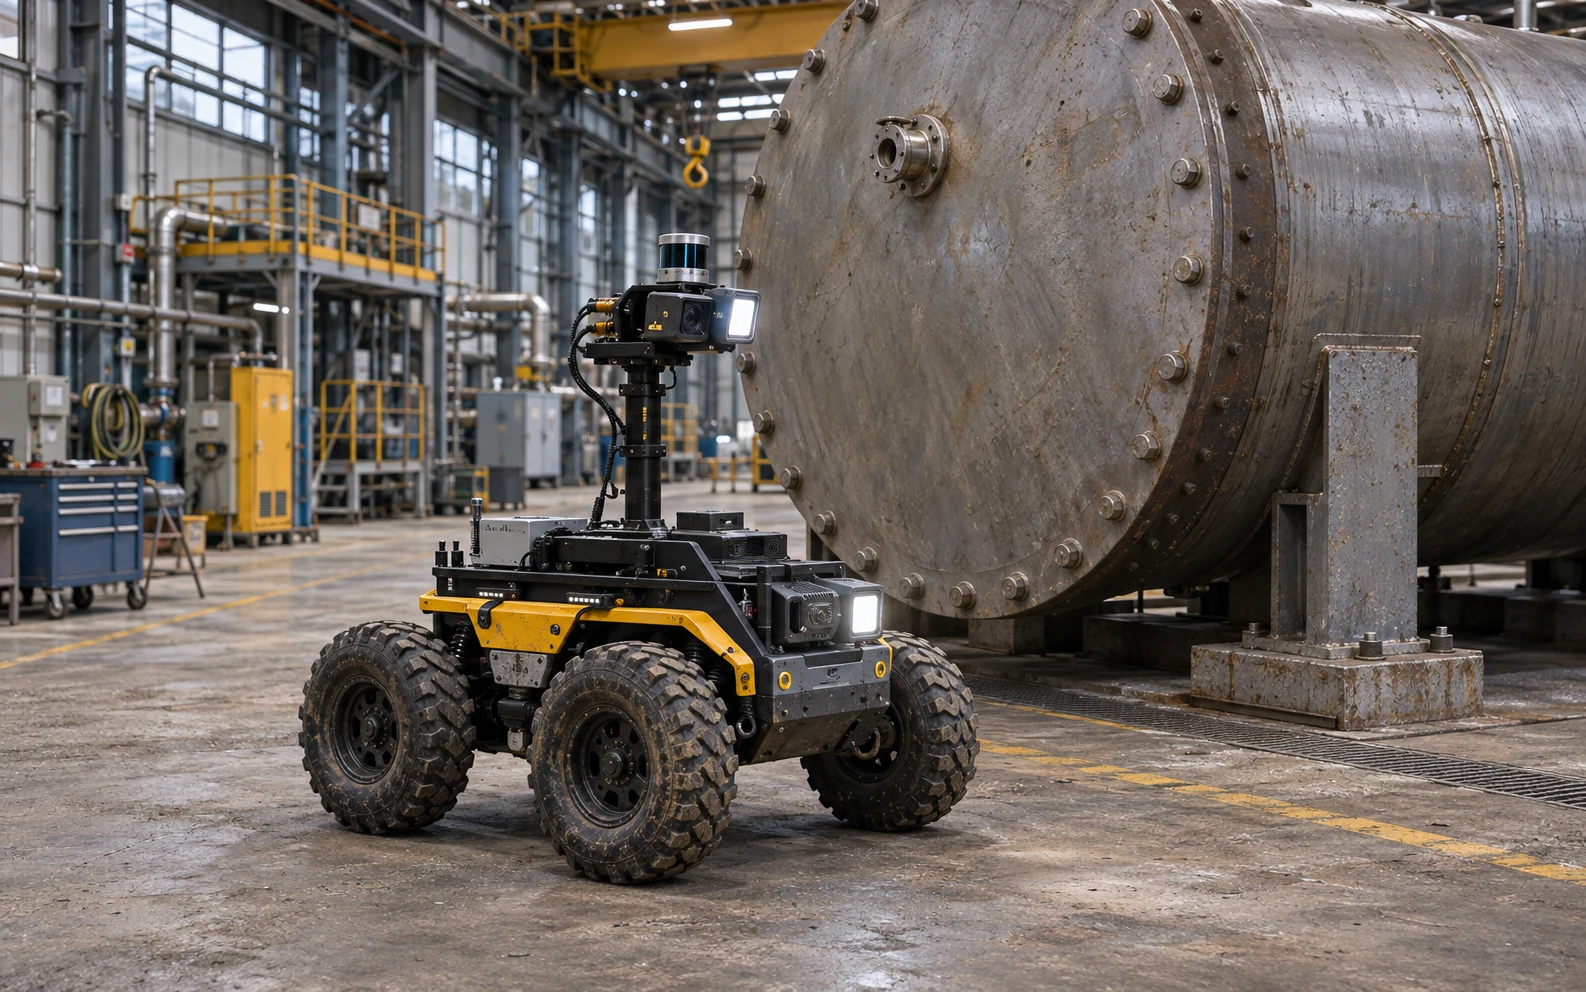
Ground robots for remote inspection of equipment and service areas.
What it is meant to address
Some areas are hard to reach or should be visited by people as rarely as possible. Robots can carry cameras and sensors along defined routes and record what they see.
How it connects to NukeReactor
Inspection results would be stored in Monitoring & Data and placed in context in the Digital Twin. Robots would support, not replace, qualified maintenance staff and required inspections.
Concept diagram
System architecture at a glance
An original diagram illustrating the intended functional connections. It is not a verified engineering drawing or a model of built hardware.

Intended sequence
How it would work
An intended sequence for a future project, not a description of completed work.
Plan a route
Inspection points and tasks defined from the digital model.
Inspect
Cameras and sensors record condition at each point.
Record
Results stored with time and location.
Review
Engineers review findings and plan maintenance.
Status
What is defined and what needs verification
Defined now
- Role: ground-level inspection support
- Integration with records and the digital model
Requires verification
- Robot platform and sensors
- Operation in the installation environment
- Access routes in an underground layout
- Procedures and qualification
Related material
Sources and related pages
No specific publications are listed for this direction yet. Our general approach to sources is described on Engineering & Sources.
- NukeReactor™Energy · Main project
- NukeDrone™Air & Autonomous
FAQ
Questions
Is the inspection robot shown a built product?
No. The picture is a generic visualization, not a manufactured product.
Robotics experience?
We are interested in inspection robotics for industrial environments.